 Xem Studiomeasured geometry
Library › Mechanisms › Gears ·
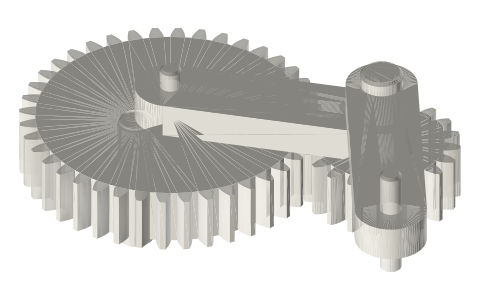
Eccentric spur gear and pinion on a swinging arm (variable speed)
How does an eccentric gear give a varying speed? · Hardware · basis: Xem Studio design following Brown No. 222 (1868)
Also called: eccentric gear drive, variable speed gear, off centre gear and pinion, engranaje excéntrico y piñón, Exzenterrad mit Ritzel
Exact dimensions. True size, with no printing tolerance added.
- sizes
- 4 in table
Notes
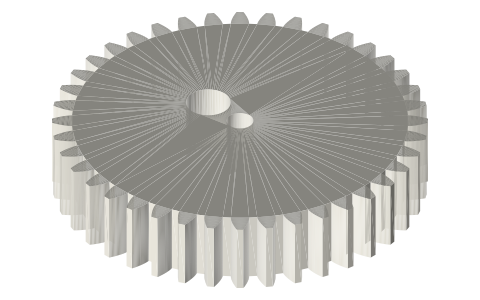
- A 40-tooth gear turns on a shaft 5 mm off its centre; a 20-tooth pinion on a swinging arm follows it, held at the exact 30 mm centre distance by a link from the gear's centre stud. The pinion's speed varies each turn as its contact point moves nearer and farther from the shaft: between about 0.75 and 1.25 of the mean 2 : 1 ratio.
- Drawn at 60° of shaft rotation: gear centre at (2.5, 4.33), pinion at (27.9, 20.29), arm pivot at (50, 0). Module 1, teeth in mesh with no backlash drawn.
- Brown's No. 222 (eccentric wheel with a link in place of the groove of No. 221).
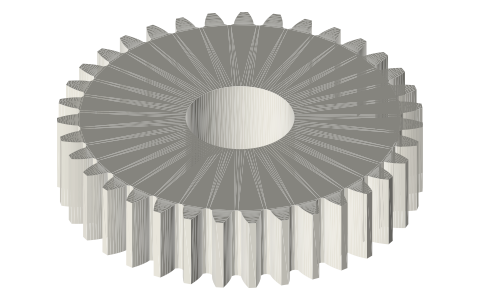
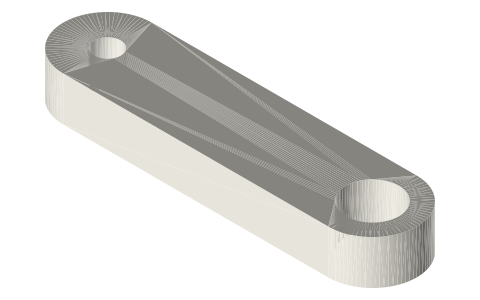
- Parts (each has its own page): eccentric-spur-gear-m1-40t-e5-b5, spur-gears-module-1, swing-arm-30-holes-3-and-6, dowel-pins-metric.
- Brown's movement No. 222 (1868) shows it; this model is a Xem Studio design following his figure, every part at true size.
Eccentric spur gear and pinion on a swinging arm size chart
| parameter | value |
|---|---|
| gear | 40 T, bore 5 mm off centre |
| pinion | 20 T on a 30 mm arm |
| link | 30 mm, centre to centre |
| speed swing | 0.75 – 1.25 × mean |
Where the files are
Other publishers' files are linked, not hosted. "verify" = check the license at the link before commercial use.
| Henry T. Brown (1868, public domain) | Five Hundred and Seven Mechanical Movements — scan on archive.org | web | Publisher's page; dimensions are facts |
| 507movements.com | Brown's movement No. 222: figure, his text and an animation | web | Publisher's page; dimensions are facts |
Free files
★ Free files 1 parts. Xem Studio design: free to use, print and sell things from; not to be republished as files. Xem Studio Design License. index.json
| eccentric-gear-and-pinion-mechanism-assembly | Assembled mechanism, all parts placed at one pose (STEP keeps each part separate) | STEP · STL |
https://xemstudio.com/mcp to Claude, ChatGPT, Cursor or any MCP client (free, no account, one minute) and it can look up exact sizes, mating fits and free STEP/STL from every chat.Plain text: sheet.txt · JSON: /api/geometry?object=eccentric-gear-and-pinion-mechanism
Fits with
Questions
How does an eccentric gear give a varying speed?
A 40-tooth gear turns on a shaft 5 mm off its centre; a 20-tooth pinion on a swinging arm follows it, held at the exact 30 mm centre distance by a link from the gear's centre stud. The pinion's speed varies each turn as its contact point moves nearer and farther from the shaft: between about 0.75 and 1.25 of the mean 2 : 1 ratio.