 Xem Studiomeasured geometry
Library › Mechanisms › Intermittent motion ·
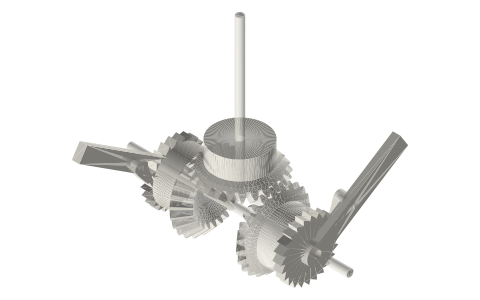
Rocking shaft driving an upright shaft continuously through two opposed ratchets and bevel gears
How can a rocking shaft drive another shaft round continuously? · Hardware · basis: Xem Studio design following Brown No. 49 (1868)
Also called: opposed ratchets, ratchet rectifier, oscillating to continuous rotation, double ratchet bevel, trinquetes opuestos con engranajes cónicos, Gegenläufige Klinkenräder mit Kegelrädern
Exact dimensions. True size, with no printing tolerance added.
- sizes
- 4 in table
Notes
- Resize: multiply every length by one factor k and the motion stays identical: angles, ratios, timing and the formulas below do not change, because a mechanism's motion depends only on the ratios of its lengths. Here, stays the same: gears, ratchets.
- Resize: fit clearances stay in mm (a slide fit is the same gap at any size); keep every printed wall and pin at least two nozzle widths; mass grows with k³ but part strength only with k², so at k = 2 parts are about 8× heavier and 4× stronger: check pins and thin links when scaling up.
- Two mitre gears ride loose on the rocking cross shaft, facing each other across a third gear on the upright shaft. Each carries a ratchet wheel; a pawl on an arm keyed to the cross shaft drives each, the two ratchets set opposite ways.
- Rocking one way, pawl A drives gear A; rocking back, pawl B drives gear B. Because A and B sit on opposite sides of the upright gear, both turn it the same way: the upright shaft goes round (almost) continuously while the cross shaft only rocks.
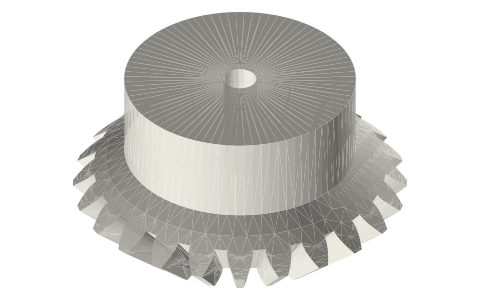
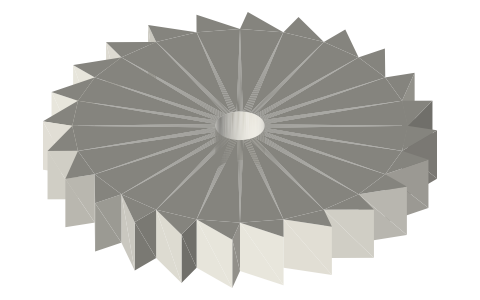
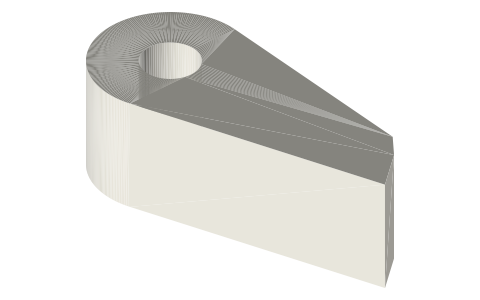
- Built from three module 2, 24-tooth spherical-involute mitre gears (cone distance 33.94 mm) and two copies of the catalog 24-tooth ratchet, feed pawl and feed arm (Brown No. 225 parts); the gears were checked in mesh at six angles. Brown's No. 49.
- Parts (each has its own page): mitre-gear-m2-24t-bore5, ratchet-wheels, ratchet-feed-pawl-24t-d40, ratchet-feed-arm-30, linear-shafts-h6.
- Brown's movement No. 49 (1868) shows it; this model is a Xem Studio design following his figure, every part at true size.
Rocking shaft driving an upright shaft continuously through two… size chart
| parameter | value |
|---|---|
| gears | 3 × mitre, module 2, 24 T |
| ratchets | 2 × 24 T Ø40, opposite hands |
| input | cross shaft rocking |
| output | upright shaft, one direction |
Where the files are
Other publishers' files are linked, not hosted. "verify" = check the license at the link before commercial use.
| Henry T. Brown (1868, public domain) | Five Hundred and Seven Mechanical Movements — scan on archive.org | web | Publisher's page; dimensions are facts |
| 507movements.com | Brown's movement No. 49: figure, his text and an animation | web | Publisher's page; dimensions are facts |
Free files
★ Free files 1 parts. Xem Studio design: free to use, print and sell things from; not to be republished as files. Xem Studio Design License. index.json
| opposed-ratchets-bevel-gears-rocking-mechanism-assembly | Assembled mechanism, all parts placed at one pose (STEP keeps each part separate) | STEP · STL |
https://xemstudio.com/mcp to Claude, ChatGPT, Cursor or any MCP client (free, no account, one minute) and it can look up exact sizes, mating fits and free STEP/STL from every chat.Plain text: sheet.txt · JSON: /api/geometry?object=opposed-ratchets-bevel-gears-rocking-mechanism
Fits with
Questions
How can a rocking shaft drive another shaft round continuously?
Two mitre gears ride loose on the rocking cross shaft, facing each other across a third gear on the upright shaft. Each carries a ratchet wheel; a pawl on an arm keyed to the cross shaft drives each, the two ratchets set opposite ways.